I built an "Electronic Nose" for Precision Agriculture (Multimodal Edge AI)
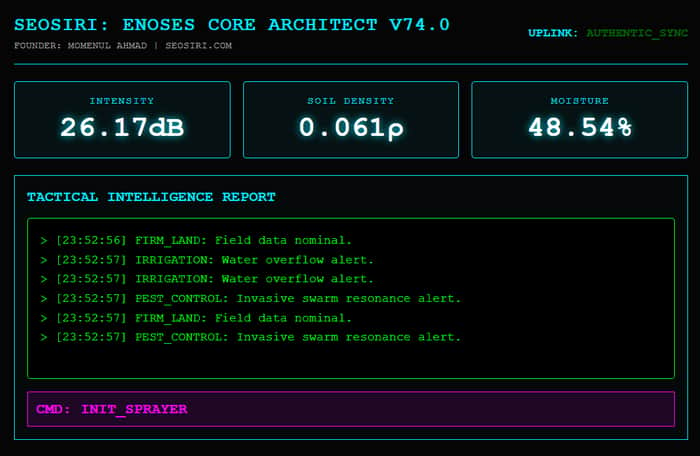
I’ve been obsessed with bridging the gap between field-level hardware and AI analytics. Today, I'm open-sourcing ENOSES, a multimodal framework that turns standard hardware into a high-fidelity sensing node.
The Tech Stack:
Edge: Python DSP + FFT (Fast Fourier Transform) on HP Pro x2 hardware to classify 9 industrial sectors (Agri, Rescue, Ocean, etc.).
Cloud: Real-time JSON telemetry via EMQX MQTT.
Vision: Live pixel-analysis for fire/lightning detection.
Robotics: An API that sends robotics_cmd (e.g., INIT_SPRAYER) directly to field units.
The "Aha!" moment: Solving the browser-hardware camera lock. By configuring the webcam as a separate thread (cv2) and piping Base64 telemetry to the UI, I got vision analytics running without a crash.
I’m looking for feedback from the community—how would you extend the multimodal sensing for your robotics projects?
🔗 Check the repo: https://github.com/SEOSiri-Official/ENOSES
🔗 See the full architectural breakdown: https://www.seosiri.com/2026/05/enoses-precision-agriculture-ai.html
#indiehackers #buildinpublic #agritech #edgeai #python
